Why Can 2,000 Photos Still Produce a Broken 3D Gaussian Splat?
Image count is not geometric evidence. Diagnose coverage, parallax and camera poses before adding more photos.
Research note ·
VISULOMA JOURNAL
Image count is not geometric evidence. Diagnose coverage, parallax and camera poses before adding more photos.
Low reprojection error is not proof of correct surfaces. Separate calibration, matching, pose and training failures.
Separate extrapolation, occlusion and view-dependent appearance, then evaluate the intended viewing envelope.
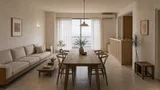
Sparse inputs can produce plausible views. Unobserved rooms still require evidence and validation.
Segmentation is only one step. Feature extraction, training losses and hidden background need separate checks.
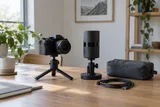
LiDAR adds geometry evidence, not a universal appearance fix. Evaluate calibration, synchronization and training integration.
Separate usability, experimental control and rendering quality. Compare the same evidence and delivery conditions.
Choose by appearance, editability, collisions and loading constraints, then validate the target experience.